Robot engineering
Structure one engineering task around requirements, Engineering Persona, Robotics Core and verification evidence.
Pilot: one engineering taskMetaCore Field combines Robotics Core, persistent Field and Engineering Personas, robot and fleet context, Digital Twin and telemetry, safety envelopes, bounded execution and verification evidence around Physical AI workflows.

The model can change. Robot context, telemetry, native safety, bounded execution and verification evidence remain organized around the Field mission.
These six paths come directly from the MetaCore Mission Router. Simulation, approved interfaces and explicit success / failure criteria come before broad physical execution.
Structure one engineering task around requirements, Engineering Persona, Robotics Core and verification evidence.
Pilot: one engineering taskRepresent one bounded asset with defined state, measurements, telemetry and evidence rather than an abstract visual replica.
Pilot: one bounded asset twinCoordinate one simulation-first multi-agent task with Fleet Context, orchestration, failure injection and a safety envelope.
Pilot: one simulated fleet taskBuild one telemetry chain with source identity, thresholds, anomaly context and verified event handling.
Pilot: one telemetry chainRun one simulated or isolated physical task through an approved execution adapter and native safety controls.
Pilot: one bounded physical taskRun one field study with defined measurements, telemetry provenance, review criteria and an Evidence Contract.
Pilot: one field studyPhysical AI is not just another tool call. The operational path needs native safety, authority, telemetry and evidence around every real-world action.

MetaCore Field connects a machine revision, work context, events, human decisions and verified outcomes. Local controllers own motion and safety; Field helps the team understand what happened and what can safely be reused.
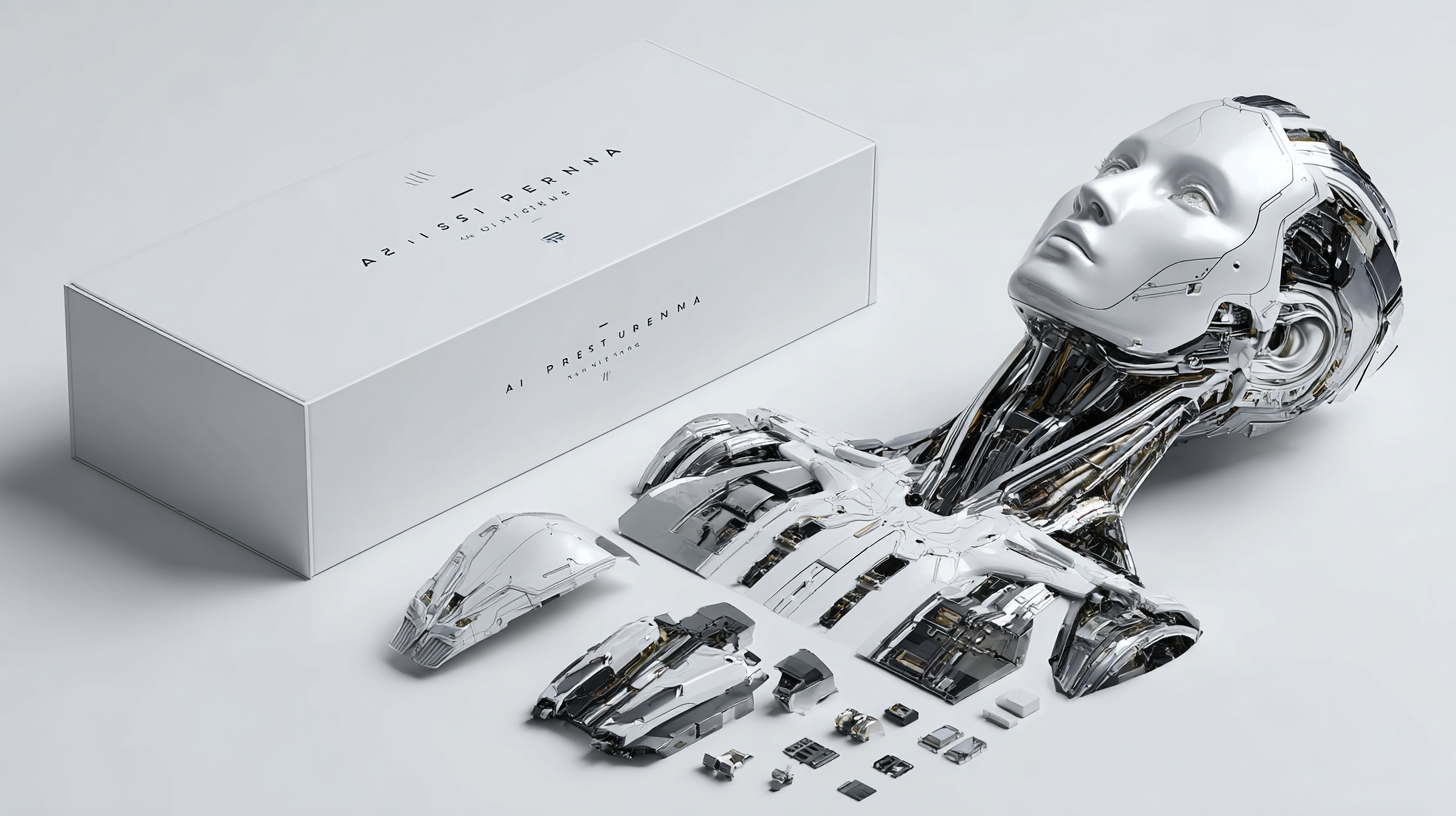
Mechanics, sensors, software and configuration share traceable engineering context, beyond a visual digital twin.
Concept illustration, not a photograph of a built MetaCore robot or equipment.
Task history, failures, recovery and validated methods remain available for the next run. This is a metaphor for operational memory, not a claim of consciousness.
Concept illustration, not a photograph of a built MetaCore robot or equipment.Start with bounded manipulation: the same robot, connector, acceptance criteria and safety envelope. Compare evidence, not only a demo impression.
This is a measurement plan, not a claimed physical test result. Local safety and human authorization remain essential.
Models plan or interpret. Native controllers and approved adapters execute. MetaCore coordinates context, authority, evidence and continuity around them.
Engineering workflow grounding, Physical AI methods, verification logic and integration discipline.
Persistent operating role around the task, platform, team and engineering history. Not autonomous physical authority.
Platform revision, environment, task history, interfaces, failures, interventions and validated experience.
Measured state and provenance for a bounded asset, sensor chain or fleet workflow.
Native hard safety remains authoritative; MetaCore adds explicit task, authority and operating boundaries around it.
Approved SDK, API, ROS2, simulator or other integration surface that separates intent from raw actuation.
Requirements, measurements, success, failure, recovery and human interventions remain reviewable.
The operating system remains: context, safety boundaries, evidence, continuity and human authority.
We separate the public category explanation from the deeper Robotics module and the bounded Field Transformation Pilot. No measured performance improvement is claimed here without pilot evidence.

The live Robotics surface covers operational coherence, robot runtime, engineering integration, sensor fusion, Physical AI and transformation-pilot engineering depth.
Bring one robot or approved integration surface, freeze the BEFORE baseline, connect MetaCore Field, repeat the same task and measure the DELTA.
Acceptance criteria, interventions, failures, recovery and resulting evidence should be compared before the scope grows.
Physical AI is a domain capability across the MetaCore product ladder. Workspace capacity and a custom industrial deployment are separate decisions.
Use eligible Field services, pilot intake and account functions without a workspace subscription.
Persistent engineering context, evidence files, outputs and Persona continuity.
For code, simulations, APIs, integration tooling, telemetry processing and bounded technical execution.
Higher-capacity enterprise execution where real simulation, telemetry, data and project scope require it.
Workshop + Operator + industrial roles, robot / fleet integration, governance, process architecture and team deployment.
Start small enough to measure honestly. Freeze the current system, agree the approved integration surface and acceptance criteria, repeat the same task through MetaCore Field and compare the evidence.

AI Persona is an operational assistant that monitors and responds. For Field, that means engineering intelligence around native safety, measured state, bounded execution, evidence and persistent operational context.
The Field Transformation Pilot is the live bounded program: freeze the BEFORE baseline, connect MetaCore Field around an approved integration surface, repeat the same task and compare evidence. Native safety stays authoritative.
Describe one robot or approved integration surface, the physical task and the safety / evidence boundary. The MetaCore deployment team will review the scope and return with the most appropriate pilot or industrial deployment path.
For Field Transformation pilots, Corporate & Team industrial deployment and custom enterprise scope. Simulation and approved interfaces come before broad physical execution.
You can change the package below. Native robot safety is never bypassed by MetaCore.
/pilot/ is the Transformation Pilot surface. This form is for company scoping and deployment requests.